Key Takeaways
Linear eigenvalue analysis is a fast elastic stability check, while GMNIA follows structural response with geometric and material nonlinearity and defined imperfections. Used together, they provide a clearer basis for buckling assessment and design decisions.
- Eigenvalue analysis identifies idealized critical load factors and likely buckling modes.
- GMNIA can account for large displacements, yielding, stiffness changes, and initial imperfections.
- Global, local, and distortional modes may interact, particularly in slender or thin-walled members.
- Reliable nonlinear results depend on realistic supports, materials, imperfections, mesh, and solution controls.
- Independent verification, code requirements, and documented convergence evidence remain essential.
Buckling fundamentals and the role of each analysis method
Buckling is a stability problem rather than simply a strength problem. A member may have sufficient material capacity under a first-order calculation and still lose its ability to carry load when a small displacement changes the internal force pattern. The appropriate analysis method depends on the structural form, expected failure mechanisms, available information, and the design decision being made.
Why stability analysis matters in structural design
A structure can become unstable before its material reaches a conventional resistance limit. Compression members, plates, shells, frames, beams subject to lateral-torsional buckling, and thin-walled aluminum sections can all be sensitive to stiffness and geometry. Stability checks therefore sit alongside strength and serviceability checks, not behind them.
The concern is especially relevant where the elastic modulus is relatively low or where members are slender. Aluminum structures, for example, can require particular attention because a lower elastic modulus reduces elastic buckling resistance, while welded heat-affected zones may have locally reduced strength. A credible assessment must connect the idealized calculation to the actual load path, restraint, fabrication, and construction condition.
Global, local, and distortional buckling modes
Global buckling involves the movement of an entire member or structural system, such as flexural, torsional, or lateral-torsional buckling. Local buckling is associated with individual plate elements in a section, while distortional buckling involves deformation of the cross-sectional shape, such as rotation or displacement of a flange and web assembly.
These modes are not always independent. A thin-walled member may experience local plate buckling while its overall axis also bends or twists. The first eigenmode may not be the only mode that matters; a higher mode can be more relevant if it matches a realistic imperfection or couples with another instability mechanism.
How stiffness, geometry, materials, and boundary conditions affect buckling
Buckling resistance is governed by more than nominal member length. Effective length, section properties, plate slenderness, connection stiffness, load eccentricity, residual stress, material response, and restraint all influence the equilibrium path. Small changes in bracing location or support rotation can materially alter the predicted mode and resistance.
For this reason, boundary conditions should describe the physical structure rather than merely make the model convenient. A pinned support, semi-rigid connection, diaphragm, or imperfect brace introduces a different stiffness environment. Mesh density matters as well: a coarse model can suppress local modes, while an unnecessarily refined model can create numerical sensitivity without improving the engineering representation.
Where linear eigenvalue analysis and GMNIA fit in the design process
Linear eigenvalue analysis is commonly used early to understand elastic stability and locate critical regions. GMNIA is then used when the design requires a closer representation of imperfections, second-order effects, yielding, or post-buckling behavior. Neither method removes the need for engineering judgment; each answers a different question.
A useful design sequence is to begin with model verification and elastic modes, then use those results to develop and challenge a nonlinear model. The GMNIA module verification for beams in bending illustrates why benchmark comparisons and clearly defined imperfection approaches matter when interpreting nonlinear results.
Linear eigenvalue buckling analysis explained
Linear eigenvalue buckling analysis treats buckling as an idealized bifurcation from a pre-buckling state. It is computationally efficient and provides a valuable map of potential instability patterns. Its output, however, should be read as an elastic reference rather than an automatic prediction of the failure load of a fabricated structure.
The eigenvalue formulation and critical load factor
In a simplified form, the stability problem can be written as the search for a factor multiplying a reference load pattern at which the tangent stiffness becomes singular. The eigenvalue is often interpreted as a critical load factor, and the associated eigenvector describes the displacement pattern at that idealized point.
If the reference load is the design load, an eigenvalue of 2.4 indicates that the idealized elastic system reaches a bifurcation at approximately 2.4 times that reference pattern. The interpretation is meaningful only when the reference loads, prestress state, restraints, and stiffness matrix have been defined correctly.
Idealized assumptions behind linear analysis
The method generally assumes small displacements, linear elastic material behavior, a perfect or idealized geometry, and a prescribed load pattern. It does not by itself capture yielding, residual stresses, measured out-of-straightness, contact changes, or the progressive loss of stiffness that can occur after instability begins.
That does not make the method weak. It makes the method specific. Linear analysis is often the right first filter because it isolates elastic sensitivity without the additional modeling choices required by a nonlinear calculation. Problems arise when its critical factor is treated as a complete resistance check for an imperfection-sensitive structure.
Identifying the governing buckling mode shape
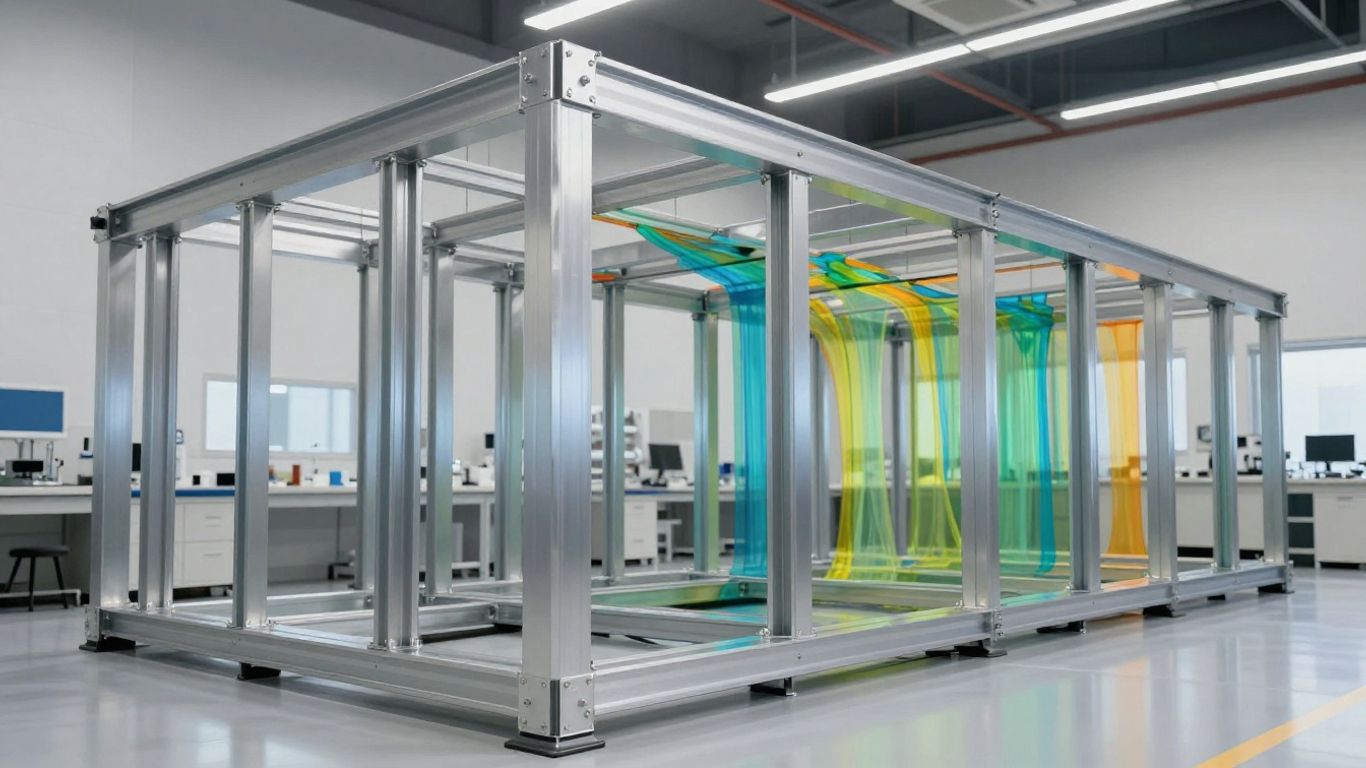
The mode shape is a diagnostic result. Engineers should review whether it is global, local, distortional, torsional, or a coupled form, and whether it is physically compatible with the actual restraints and loading. A mathematically low mode can be irrelevant if the structure has a brace or connection that prevents that deformation pattern.
Mode shapes are normalized eigenvectors, so their displayed amplitude has no direct physical meaning. Their value lies in the location and character of movement. They can reveal weak regions, unexpected releases, disconnected components, inadequate diaphragm action, or a mesh that is too coarse to resolve a local plate mode.
Strengths and limitations for real structures
The principal strengths are speed, clarity, and usefulness for screening alternatives. The limitations follow from the idealization: the result can be unconservative when imperfections and plasticity reduce resistance, but it can also be misleadingly conservative or irrelevant when the computed mode is not physically admissible.
A sensible report states the reference load, material model, boundary conditions, number of modes reviewed, and interpretation of the critical factor. It should also distinguish a first elastic bifurcation from an ultimate limit-state resistance. Where the decision depends on nonlinear response, eigenvalue analysis should guide the next model rather than close the assessment.
Geometrically and materially nonlinear analysis with imperfections
GMNIA stands for Geometrically and Materially Nonlinear Analysis with Imperfections. It follows equilibrium while the structure changes shape and material stiffness, beginning from an imperfect geometry or stress state. That makes it a response-based approach, capable of addressing interactions that a single idealized eigenvalue cannot describe.
How GMNIA captures large-displacement behavior
Geometric nonlinearity updates the relationship between displacement and internal force as the structure deforms. P-delta effects, rotation changes, second-order moments, contact changes, and snap-through tendencies can therefore influence the calculated response. The analysis may follow the structure beyond the point where a first-order model would no longer be meaningful.
The calculation is incremental. Loads are applied through steps, equilibrium is sought at each step, and the stiffness used for the next step reflects the current state. This provides a load-deflection path rather than only a single critical multiplier. The quality of that path depends on whether the model contains the mechanisms that actually control the structure.
Material nonlinearity, yielding, and stiffness degradation
Material nonlinearity allows stress and strain to depart from a purely elastic relationship. Depending on the chosen constitutive law, the model can capture yielding, plastic redistribution, strain hardening, unloading, and reduced tangent stiffness. These choices are particularly relevant when buckling and plasticity interact.
Material data must match the structural situation. Aluminum requires care because it has no sharply defined yield point in the same way as idealized structural steel and may show significant strain hardening. Welded zones may also need distinct properties where fabrication has reduced local strength. The model should not imply a precision that the test data, specification, or code provisions do not support.
Initial geometric imperfections and residual stresses
No manufactured member is perfectly straight, and no assembled frame is perfectly aligned. An imperfection can be introduced from a measured survey, a specified fabrication tolerance, a code-based amplitude, or a scaled buckling mode. Residual stresses from rolling, welding, cutting, or forming may be modeled separately when they are relevant and sufficiently characterized.
Imperfections should be selected with a clear rationale. A global mode may be appropriate for overall member instability, while a local mode may be needed for plate buckling. Combining modes can be useful, but arbitrary combinations can produce an untraceable result. The GMNIA design discussion describes the method as accounting for both plasticity and buckling failure modes, which is the central reason its inputs must be treated deliberately.
Load-deflection response and post-buckling behavior
The defining advantage of GMNIA is that it can show how resistance develops and changes, rather than identifying only an ideal bifurcation. A response curve may include an initial elastic range, stiffness reduction, local yielding, a peak resistance, and a descending or stabilized post-buckling branch. Whether that post-buckling branch is physically meaningful depends on the model and the structure’s ability to redistribute load.
A peak on a numerical curve is not automatically the design resistance. Engineers should check whether the governing limit state is excessive deformation, rupture, local collapse, connection failure, material fracture, or loss of equilibrium. The GMNIA analysis overview provides a useful general explanation of how material deformation, buckling, and imperfections are considered together.
Building a reliable GMNIA model
A nonlinear model is only as reliable as its physical assumptions. More elements, smaller load steps, and a sophisticated solver cannot compensate for incorrect restraint or an imperfection with no engineering basis. Model development should therefore proceed from the real load path and failure mechanism, with each assumption recorded before the results are reviewed.
Selecting imperfection shapes and amplitudes
Start by reviewing elastic eigenmodes and construction information. Select modes that are compatible with the expected instability, then assign amplitudes from measurement, tolerance requirements, code provisions, or a justified sensitivity range. The sign of an imperfection can matter when load eccentricity, asymmetric restraint, or coupled modes are present.
A useful sensitivity set often includes the nominal imperfection, a less favorable credible value, and an alternative mode or combination. This is not a substitute for specifying a realistic fabrication tolerance. It is a way to determine whether the design conclusion depends on a narrow and uncertain assumption.
Applying realistic material and section properties
Use section properties that reflect the modeled geometry, including thickness loss, holes, welds, effective widths, and local reductions where appropriate. The constitutive model should state elastic properties, yield or proof parameters, hardening assumptions, ultimate strain limits, and any temperature or fabrication effects relevant to the case.
For aluminum, the lower elastic modulus and heat-affected zones near welded connections deserve particular attention. For steel, residual stress patterns and residual capacity after local yielding may be more influential. In both cases, section classification and element formulation should be consistent with the intended failure mode.
Representing supports, connections, and load introduction
Supports and connections control how forces enter and leave the model. A rigid constraint where the real connection slips can inflate resistance; a pin where the real joint supplies rotational restraint can suppress a realistic mode. Bolts, welds, bearing surfaces, diaphragms, braces, and contact interfaces should be idealized at the level needed to capture their structural role.
Load introduction deserves equal care. A concentrated nodal load may create a local singularity or an unrealistic distribution, while a pressure or line load may better reflect the physical contact. Where load eccentricity drives torsion or local bending, it should be represented explicitly rather than absorbed into an unexplained factor.
Defining nonlinear solution controls and convergence criteria
Nonlinear solvers need controlled load increments, tolerances, iteration limits, and sometimes arc-length or displacement-control procedures. Convergence should be judged using force residuals, displacement increments, energy criteria, and the continuity of the response, not simply the appearance of a completed run.
The controls should help distinguish physical instability from numerical difficulty. A smaller increment may resolve a sharp stiffness change, while arc-length control may follow a path through a limit point. Excessively relaxed tolerances can make a curve look smooth while allowing substantial equilibrium error.
Modeling staged loading and relevant failure mechanisms
The sequence of loading can change the state from which buckling develops. Dead load, prestress, self-weight, temporary works, imposed displacement, wind, thermal action, and service equipment may need to be introduced in stages. Installation tolerances or support settlement may also matter when they alter initial forces.
Before solving, define what constitutes failure for the assessment. It may be a maximum displacement, a strain limit, material fracture, local plate collapse, connection failure, or inability to sustain additional load. A model that omits the controlling mechanism can produce a precise but incomplete answer.
Comparing results from eigenvalue analysis and GMNIA
The two methods should not be compared as though they produce interchangeable numbers. Eigenvalue analysis identifies an idealized elastic bifurcation, whereas GMNIA follows an imperfect structure through changing geometry and material state. Differences are expected and often provide useful information about the governing behavior.
Differences in predicted critical loads and resistance
An eigenvalue factor may be substantially higher than the ultimate resistance from GMNIA because the perfect elastic model has no initial out-of-straightness, residual stress, or yielding. The reverse can occur when the eigenmode does not represent the actual restraint or when the nonlinear model includes stabilizing membrane action and reserve capacity.
The comparison should therefore ask what each result means. The eigenvalue is a stability indicator tied to a reference load pattern. The GMNIA peak is a model-dependent resistance subject to its material law, imperfection, mesh, and failure criteria. Neither number should be transferred into a code check without the appropriate safety format.
Interpreting mode shapes versus equilibrium paths
A mode shape answers, “What deformation pattern is associated with the idealized instability?” An equilibrium path answers, “How does this imperfect structure respond as load increases?” The former helps locate and classify weakness; the latter helps assess progression, redistribution, and possible collapse.
Reviewing them together is more informative than reviewing either alone. If the GMNIA deformation resembles the critical eigenmode, the linear result has helped identify the controlling mechanism. If the nonlinear path develops a different deformation, investigate contact, boundary conditions, material behavior, and mode interaction rather than assuming the solver is wrong.
Understanding sensitivity to imperfections and mesh density
Imperfection sensitivity is expected in slender members, shells, thin plates, and structures close to a bifurcation. Mesh density can influence the onset and shape of local buckling, while element formulation can affect membrane action, bending stiffness, and plastic strain localization.
A practical comparison should vary one modeling feature at a time. The following checks are usually more informative than simply refining everything at once:
- Compare at least two credible imperfection amplitudes or patterns.
- Refine the mesh in regions where local curvature or plastic strain concentrates.
- Check whether the support and load-introduction idealizations change the mode.
- Confirm that the response is not controlled by an artificial element distortion or constraint.
These checks help separate physical sensitivity from numerical sensitivity. If small, reasonable changes produce a large change in resistance, the design conclusion should carry that uncertainty explicitly.
Diagnosing divergence, instability, and nonconvergence
Nonconvergence is not automatically proof of structural failure, and convergence is not proof of safety. A solver may stop because of a sharp limit point, excessive distortion, contact switching, an unsuitable increment, or an inconsistent constraint. Conversely, a poorly configured analysis can converge to a response that does not represent the intended structure.
Review residuals, iteration history, deformed shapes, reaction forces, plastic zones, and energy balance. Test whether a smaller step, displacement control, or a corrected contact definition changes the outcome. A physical collapse mechanism should be distinguishable from a numerical artifact and explained in the report.
Using linear results to validate and initialize nonlinear analysis
Eigenmodes provide a disciplined starting point for selecting imperfection shapes and locating regions that need mesh refinement. They also act as a verification screen: unexpected rigid-body modes, disconnected parts, or implausibly low factors should be resolved before launching GMNIA.
For more specialized workflows, IDEA StatiCa Member describes the use of LBA results to help determine whether MNA or GMNIA is required. The broader lesson is transferable: use linear stability results to interrogate the model and plan the nonlinear analysis, not to bypass it when nonlinear behavior governs.
Practical workflow for buckling assessment
A sound buckling assessment is a sequence of checks rather than a single software command. The sequence should move from basic model integrity to elastic stability, then to nonlinear response where the risk and design question justify it. This keeps expensive analysis focused and makes the final conclusion easier to audit.
Start with model verification and elastic stability checks
Verify geometry, units, connectivity, section orientation, material assignment, load combinations, restraints, and reaction equilibrium. Review the undeformed model visually and compare simple members or subassemblies with hand calculations. Only after these checks should the elastic eigenvalue solution be used as a stability screen.
The initial eigenvalue run should include enough modes to reveal alternate mechanisms, not just the lowest factor. Review whether the first modes are physical and whether the model has unintended mechanisms. These basic checks often identify modeling errors earlier than a nonlinear run would.
Use eigenmodes to identify critical regions and imperfection patterns
Classify each relevant mode and map it to the structure’s fabrication and restraint conditions. A global mode may guide an overall bow imperfection, while a local mode may identify a plate region requiring finer discretization. Coupled modes deserve special attention where torsion, local plate movement, and frame sway interact.
The mode shape should also guide monitoring locations. Track displacement, stress, strain, and reaction behavior where the mode predicts concentration. That makes the later GMNIA results easier to interpret and helps avoid judging the model solely by one global displacement.
Run GMNIA load cases and sensitivity studies
Build the nonlinear model from the verified baseline. Introduce imperfections transparently, apply loads in the physical sequence, and use solution controls suited to the expected response. Run the governing combinations and a limited but meaningful sensitivity matrix rather than generating many unexplained variants.
The sensitivity cases should target real uncertainties: imperfection amplitude, imperfection sign, material hardening, connection stiffness, mesh refinement, or load eccentricity. A GMNIA-based design framework is one example of work that examines nonlinear interaction, plasticity, strain hardening, and resistance prediction; such technical references can inform the choice of what to test, while the project-specific model remains decisive.
Check member forces, stresses, displacements, and utilization
Do not reduce the review to the peak load factor. Check member forces, support reactions, displacement compatibility, stress and strain fields, plastic zones, local buckling, connection actions, and serviceability response. For aluminum members, include attention to welded heat-affected zones and the interaction of local, distortional, and global instability where relevant.
A result can pass one metric and fail another. A stable global response may coexist with excessive local strain, connection distress, or a serviceability limit being exceeded. Utilization should therefore be tied to the stated limit state and code criterion, with the governing location and load combination identified.
Document assumptions, convergence evidence, and governing results
The report should record the model version, element types, mesh strategy, material curves, imperfection basis, support definitions, load stages, solver controls, convergence criteria, and result-processing method. Include enough figures and intermediate checks for another engineer to understand how the conclusion was reached.
State clearly whether the reported value is an elastic bifurcation factor, a nonlinear peak resistance, a serviceability response, or another defined quantity. A concise independent review of assumptions and results is often more valuable than a long output file with no interpretation.
Choosing the appropriate technique for design decisions
Technique selection should follow the structural question. If the aim is to identify weak modes during concept development, linear eigenvalue analysis may be the most efficient tool. If the aim is to establish resistance for a slender, imperfect, yielding, or strongly nonlinear structure, GMNIA may be necessary.
When linear eigenvalue analysis is sufficient
Linear analysis can be sufficient for preliminary sizing, elastic stability screening, mode identification, and structures whose governing code method is explicitly based on elastic critical effects with appropriate imperfection or reduction factors. It is also useful for routine members where the response remains within the assumptions of the design method.
That sufficiency depends on verification. The model must represent the correct boundary conditions and load path, and the design procedure must explain how the elastic critical result becomes a resistance check. A high eigenvalue alone is not evidence that all strength, serviceability, connection, and detailing requirements are satisfied.
When GMNIA is needed for slender or imperfection-sensitive structures
GMNIA becomes more compelling when large displacements alter the load path, material yielding interacts with buckling, local and global modes couple, or imperfections materially affect capacity. Slender shells, thin-walled sections, sensitive frames, and structures with significant post-buckling behavior often fall into this category.
It is also useful when a conventional classification or effective-width approach does not adequately describe the interaction of elements and material response. The model still needs a defensible code basis and validation strategy; numerical sophistication is not a replacement for appropriate engineering assumptions.
Combining analysis methods for efficient engineering workflows
The most efficient workflow is usually hierarchical. Use simplified calculations and linear modes to screen alternatives, identify critical regions, and challenge the baseline model. Reserve detailed GMNIA for governing cases and for questions that cannot be answered reliably by an elastic method.
This combination reduces unnecessary computation while preserving a strong verification trail. It also makes nonlinear results easier to explain: the reader can see which mode was identified first, how the imperfection was selected, and why the final response differs from the idealized elastic factor.
Considering design codes, safety factors, and acceptance criteria
The analysis method must be compatible with the governing standard and authority requirements. Depending on the project, this may involve Eurocodes, Singapore Standards, BS provisions, ACI requirements, or other applicable national rules. The code may prescribe imperfection amplitudes, material parameters, resistance factors, strain limits, serviceability criteria, or validation requirements.
Do not mix a characteristic nonlinear resistance with a factored design action without checking the intended safety format. Define the limit state, partial factors, load combinations, acceptance thresholds, and any required independent checking before interpreting the output. For projects requiring authority submission or international engineering endorsement, this traceability is part of the technical deliverable.
Selecting software and reviewing results independently
Software should be selected for its element formulations, nonlinear material capabilities, geometric nonlinearity, imperfection handling, solver controls, output quality, and verification record. A familiar interface is not enough if it cannot represent the failure mechanism under review.
Independent review should include a second calculation, simplified benchmark, alternative model, or hand check where practical. The reviewer should inspect assumptions and equilibrium, not just compare final numbers. For complex projects, formal analysis review and design checking provide a useful structure for confirming that the method is appropriate and the results are reproducible.
Conclusion
Linear eigenvalue analysis and GMNIA are complementary techniques: one reveals idealized elastic stability patterns, while the other can follow an imperfect structure through geometric change, material nonlinearity, and resistance development. The strongest buckling assessments use both with clear assumptions, verified models, sensitivity checks, and code-aligned interpretation. That process turns a software result into an engineering conclusion that can be reviewed and defended.
Frequently Asked Questions
What does GMNIA stand for?
GMNIA stands for Geometrically and Materially Nonlinear Analysis with Imperfections. It considers changes in structural geometry, nonlinear material response, and initial imperfections within one analysis framework.
What is the main purpose of linear eigenvalue buckling analysis?
Its main purpose is to identify idealized elastic critical load factors and associated buckling mode shapes. It is commonly used for stability screening, mode classification, and planning more detailed analysis.
Does a low eigenvalue always mean the structure will fail at that load?
No. The eigenvalue belongs to an idealized elastic model and is not automatically an ultimate resistance. Imperfections, yielding, residual stress, connection behavior, and code safety formats can change the actual design conclusion.
Why are imperfections included in GMNIA?
Real structures contain fabrication, assembly, and alignment deviations. Including a defined imperfection allows the analysis to assess how those deviations influence stiffness, load redistribution, buckling, and resistance.
Can GMNIA show post-buckling behavior?
It can follow post-buckling response when the model, solver controls, material law, and structural mechanisms support that calculation. The resulting branch must still be checked for physical meaning and relevant failure limits.
How does mesh density affect buckling results?
Mesh density affects the ability to represent local curvature, plate buckling, strain localization, and connection behavior. A convergence or sensitivity study is needed to distinguish physical response from mesh-dependent numerical behavior.
Should eigenvalue analysis and GMNIA be used together?
Often, yes. Eigenvalue analysis can identify likely modes and critical regions, while GMNIA can assess the nonlinear response where imperfections, large displacements, or yielding are important. The two results should be interpreted according to their different purposes.